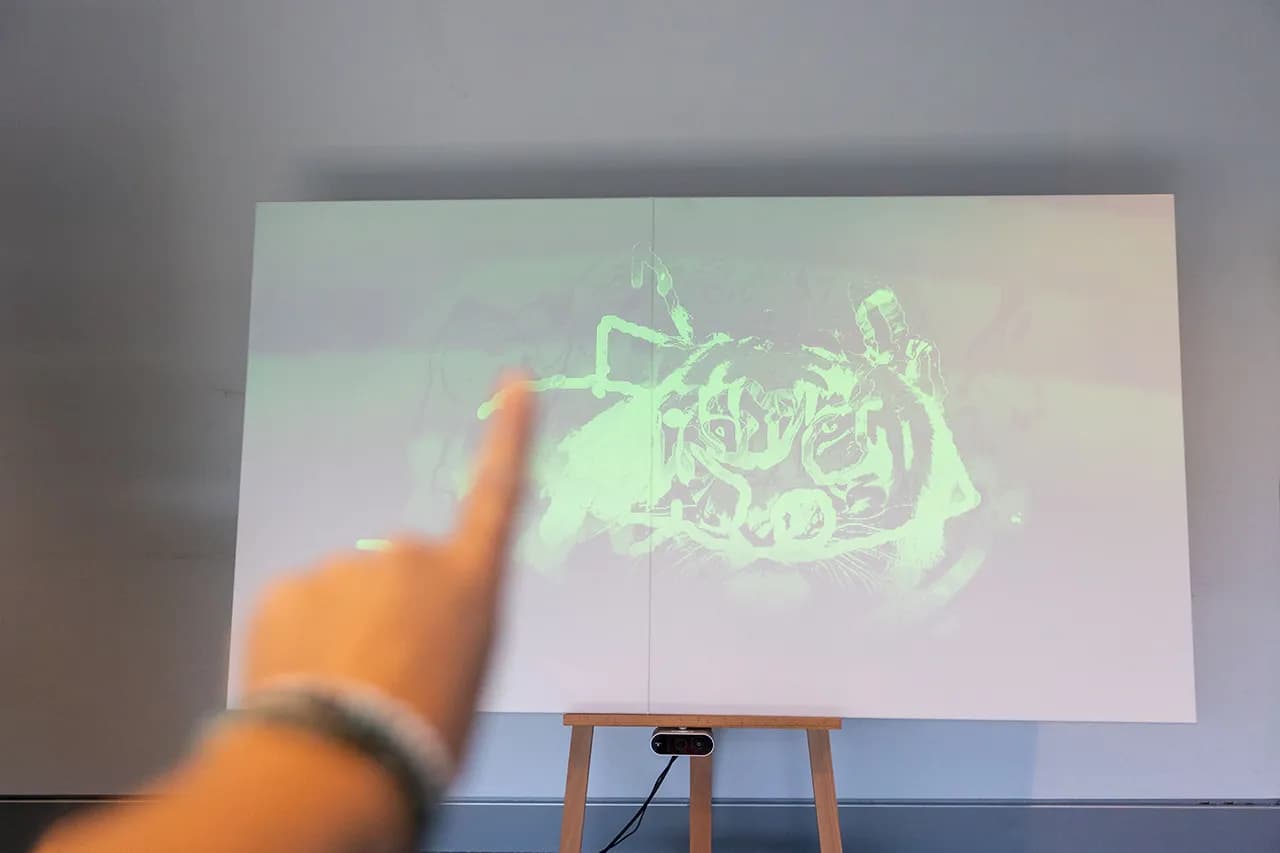
A study led by Pierre Beckmann, from the Neuro-symbolic AI Group at Idiap, explores these questions through TaxiGPT, a transformer trained on random journeys through Manhattan. Transformers are the architecture behind today’s large language models. Here, a street network provides a controlled setting where researchers can compare a model’s internal representations with the environment it navigates.
Earlier research had interpreted TaxiGPT’s navigation errors as evidence of an incoherent internal map. Looking inside its computations, the team instead found a highly faithful map of the street network, together with mechanisms for tracking the model’s position and choosing a direction.
This left an apparent contradiction: the model could accurately encode the streets but still be prone to some navigation errors. The researchers resolved the contradiction by showing that errors emerged when overlapping representations of intersections interfered with localization. Through targeted interventions, they established how those representations influence navigation and showed that strengthening the correct position signal or suppressing interference reduced errors. They also found that intersections allowing the same turns have similar representations, helping some localization mistakes remain harmless.
For the broader study of AI reasoning, the work illustrates why unfamiliar computational strategies deserve investigation on their own terms. Human analogies remain hypotheses to test. Its central contribution is a more precise account of how representing an environment, locating oneself within it and acting successfully depend on distinct, interacting mechanisms.
Reference:
Beckmann, P., Queloz, M., & Freitas, A. (2026). World Modeling in Transformers. arXiv:2609.21748.
Interactive démo: https://pierrebeckmann.com/world-modeling/